Gagan Bhusal
Robotics and Machine Learning researcher studying Electronics, Communication & Information Engineering at IOE Pulchowk Campus.
Selected Projects & Research
Click any project to view technical overview & demosUnitree Go2 Sim-to-Real Quadruped Locomotion
2026Trained an asymmetric actor-critic locomotion policy across 4,096 parallel environments in Genesis simulator with aggressive domain randomization. Transferred zero-shot to the physical Unitree Go2 via low-level CycloneDDS, validating stable standing, push recovery, and blind omnidirectional walking.
Unitree G1 Humanoid Motion Imitation
In Progress · 2026Building an end-to-end whole-body motion imitation pipeline for the 23-DOF Unitree G1 humanoid robot. Video pose recovery (GVHMR) and kinematic retargeting (GMR) are functional; currently training whole-body tracking via Asymmetric Actor-Critic PPO in Genesis and Mjlab, with sim-to-real transfer pending.
AlphaZero from Scratch for Connect-4 Agent
2025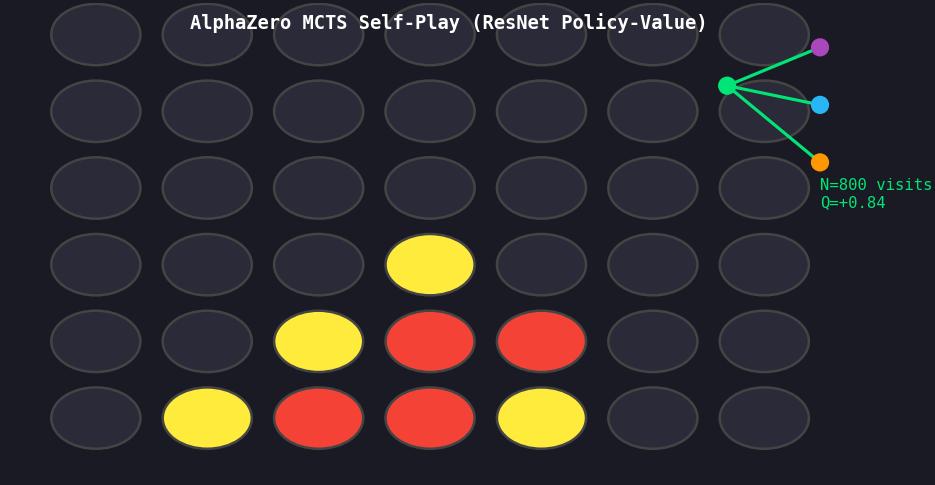 MCTS EVALUATION
PyTorch implementation of DeepMind's AlphaZero algorithm for two-player Connect-4. Uses Monte Carlo Tree Search (MCTS), a residual policy value neural network, and self-play data generation without human domain knowledge. Outperformed depth-10 Minimax agents.
Ghost-Net: Edge AI Forest Bioacoustics
2026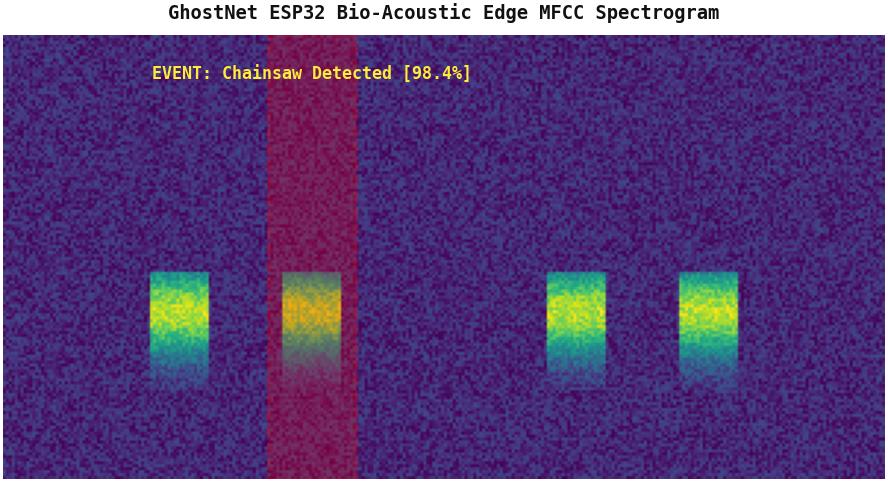 MFCC SPECTROGRAM
Autonomous bioacoustic surveillance node for detecting illegal logging (chainsaws), gunshots, and weather patterns. Designed an ultra-compact CNN trained on MFCC audio spectrograms, quantized to INT8 with 74.6% accuracy, and deployed onto an ESP-32 microcontroller with TensorFlow Lite Micro.
Satellite Image Super-Resolution & Spatial Upscaling
2026 · Current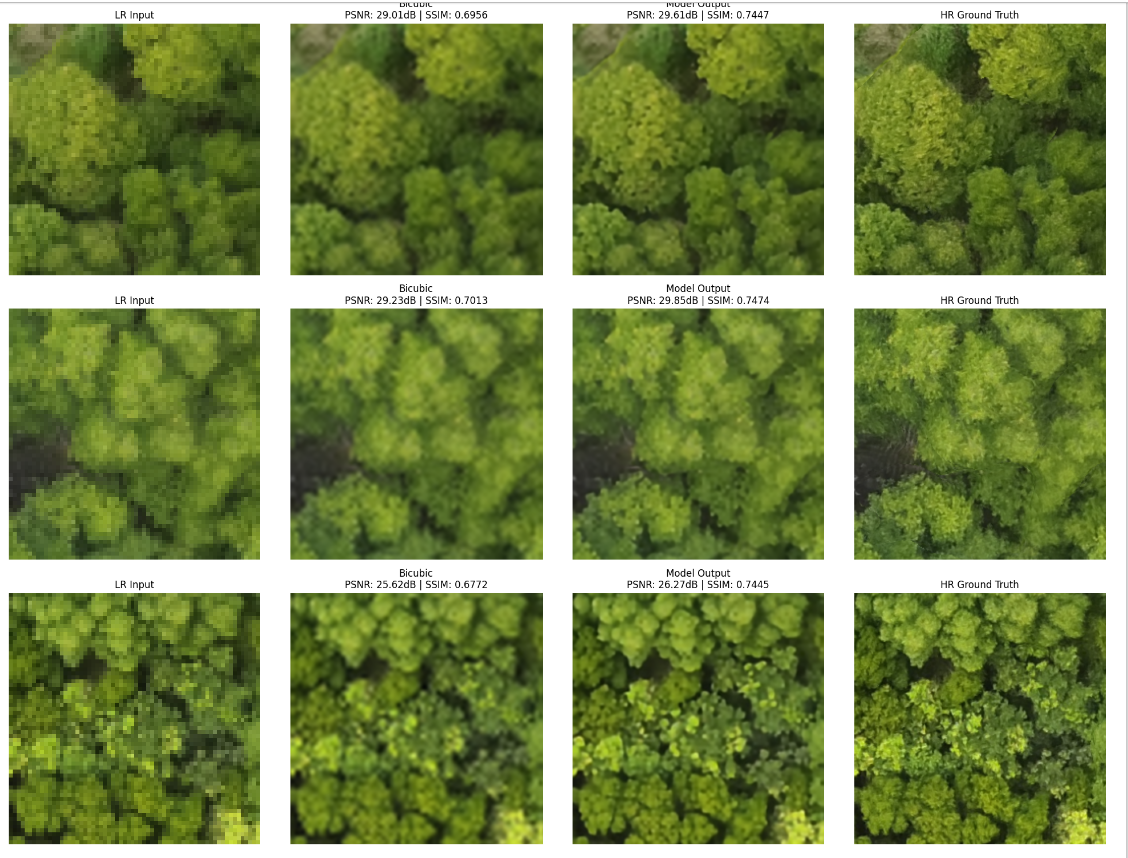 4X SUPER-RESOLUTION
Contributing to a PhD research project on deep learning-based spatial super-resolution for multi-band satellite imagery. Built data pipelines processing paired large-scale UAV ground-truth tiles with spatial-leakage prevention, and benchmarked CNN vs. Vision Transformer restoration backbones in PyTorch. Unpublished, under NDA.
Physics-Informed Neural Networks (PINNs)
2025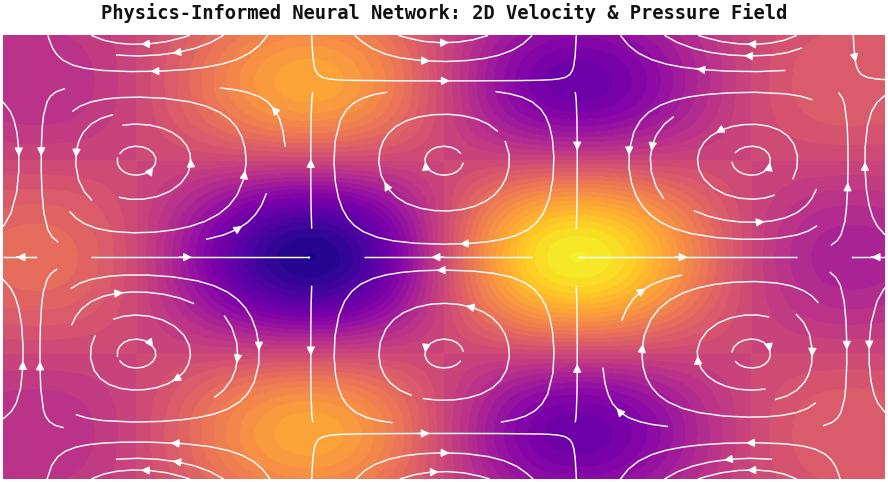 2D PDE FLOW FIELD
Deep learning framework for solving arbitrary non-linear ODEs and PDEs without labeled data, validated against the 1D heat equation. Includes an interactive Streamlit application supporting user-defined equations and 3D solution visualization.
Open-Source 8-DOF Quadruped Robot
2025Co-engineered an open-source 8-DOF quadruped robot. Implemented inverse kinematics on an Arduino for real time leg trajectory planning and control, and deployed a custom on-device wake-word model on an ESP-32 for voice command triggers.
English to Nepali Machine Translation with Custom Transformer
2024–2025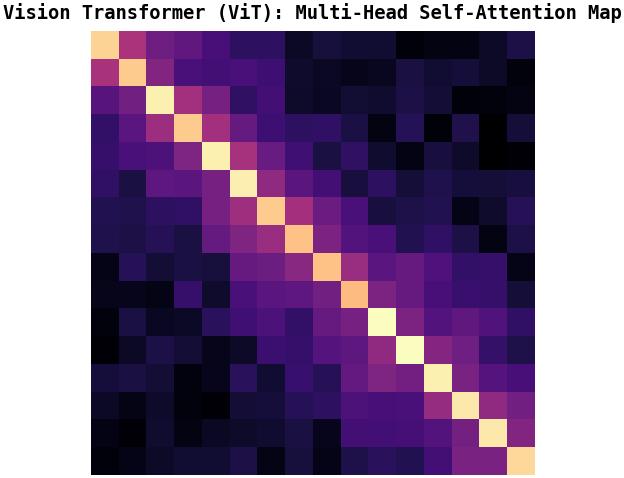 SELF-ATTENTION MAP
Built an encoder-decoder Transformer from scratch in PyTorch. Hand-coded multi-head self-attention, positional embeddings, causal masking, and evaluated translation performance from English to Nepali with BLEU and chrF scoring.
Experience
Research • Engineering Roles- Owned the low-level sim-to-real deployment pipeline for the Unitree Go2 quadruped, engineering custom CycloneDDS communication bridges, hardware joint mappings, and two-phase Kp/Kd gain scheduling to eliminate sim-to-hardware observation mismatches.
- Delivered a standardized policy deployment and safety watchdog toolkit used by lab researchers to benchmark learning-based locomotion controllers safely on physical robot hardware.
- Collaborated closely with RAN hardware and robotics team members during physical trials to diagnose motor thermal limits, calibrate IMU state estimators, and validate zero-shot push recovery and omnidirectional walking.
- Engineering deep learning pipelines in PyTorch for spatial super-resolution and upscaling of multispectral satellite imagery using paired UAV orthomosaics as ground truth.
- Built large-scale tile pairing pipelines and designed geographic train/test splits across regions to eliminate spatial autocorrelation leakage. (Unpublished, under NDA)
- Co-developed the open-source 8-DOF Quadruped Robot, leading inverse kinematics for gait planning and control.
- Trained and quantized a custom wake-word detection model, deployed it on an ESP-32.